NURing: A Tendon-Driven Wearable Ring for On-Demand Kinesthetic Haptic Feedback
Tomasz Trzpit, Gregory Reardon, Anthony Shilati, Elizabeth M. Gerber, Michael A. Peshkin, J. Edward Colgate (2025)
IEEE World Haptics Conference
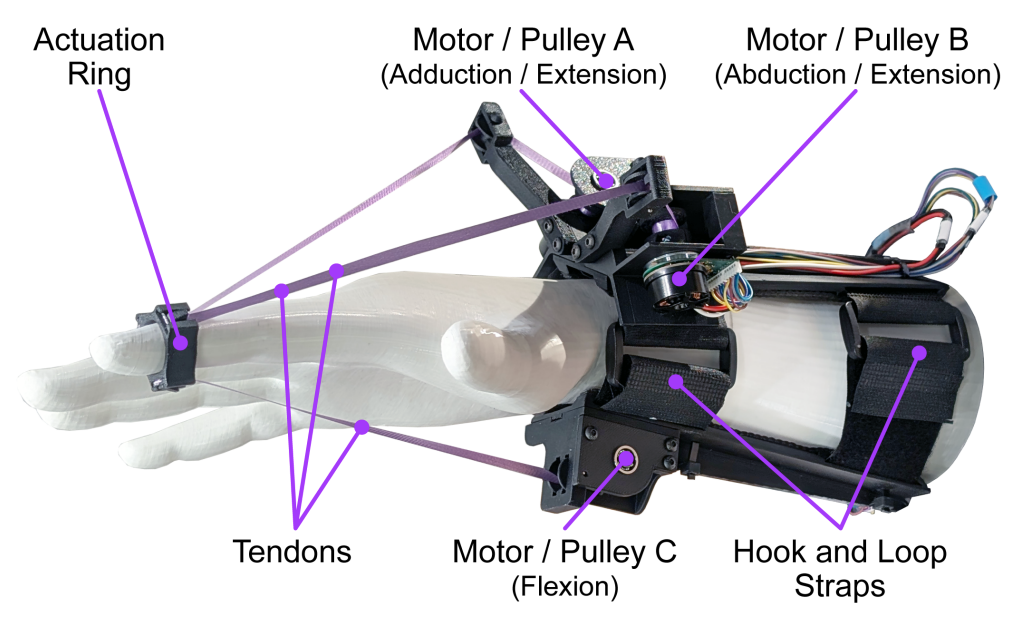
Generating salient and intuitively understood haptic feedback on the human finger through a non-intrusive wearable remains a challenge in haptic device development. Most existing solutions either restrict the hand and finger’s natural range of motion or impede sensory perception, quickly becoming intrusive during dexterous manipulation tasks. Here, we introduce NURing (Non-intrUsive Ring), a tendon-actuated haptic device that provides kinesthetic feedback by deflecting the finger. The NURing is easily donned and doffed, enabling on-demand kinesthetic feedback while leaving the hand and fingers free for dexterous tasks. We demonstrate that the device delivers perceptually salient feedback and evaluate its performance through a series of uniaxial motion guidance tasks. The lightweight NURing device, measuring approximately 220 g, can generate guidance cues at up to 1 Hz, enabling participants to identify target directions in under 3s with a 1.5° steady-state error, corresponding to a fingertip deviation of less than 11 mm. Additionally, it can guide users along complex, smooth trajectories with an average trajectory error of 7°. These findings highlight the effectiveness of fingertip deflection as a kinesthetic feedback modality, enabling precise guidance for real-world applications such as sightless touchscreen navigation, assistive technology, and both industrial and consumer augmented/virtual reality systems.